Paper 7

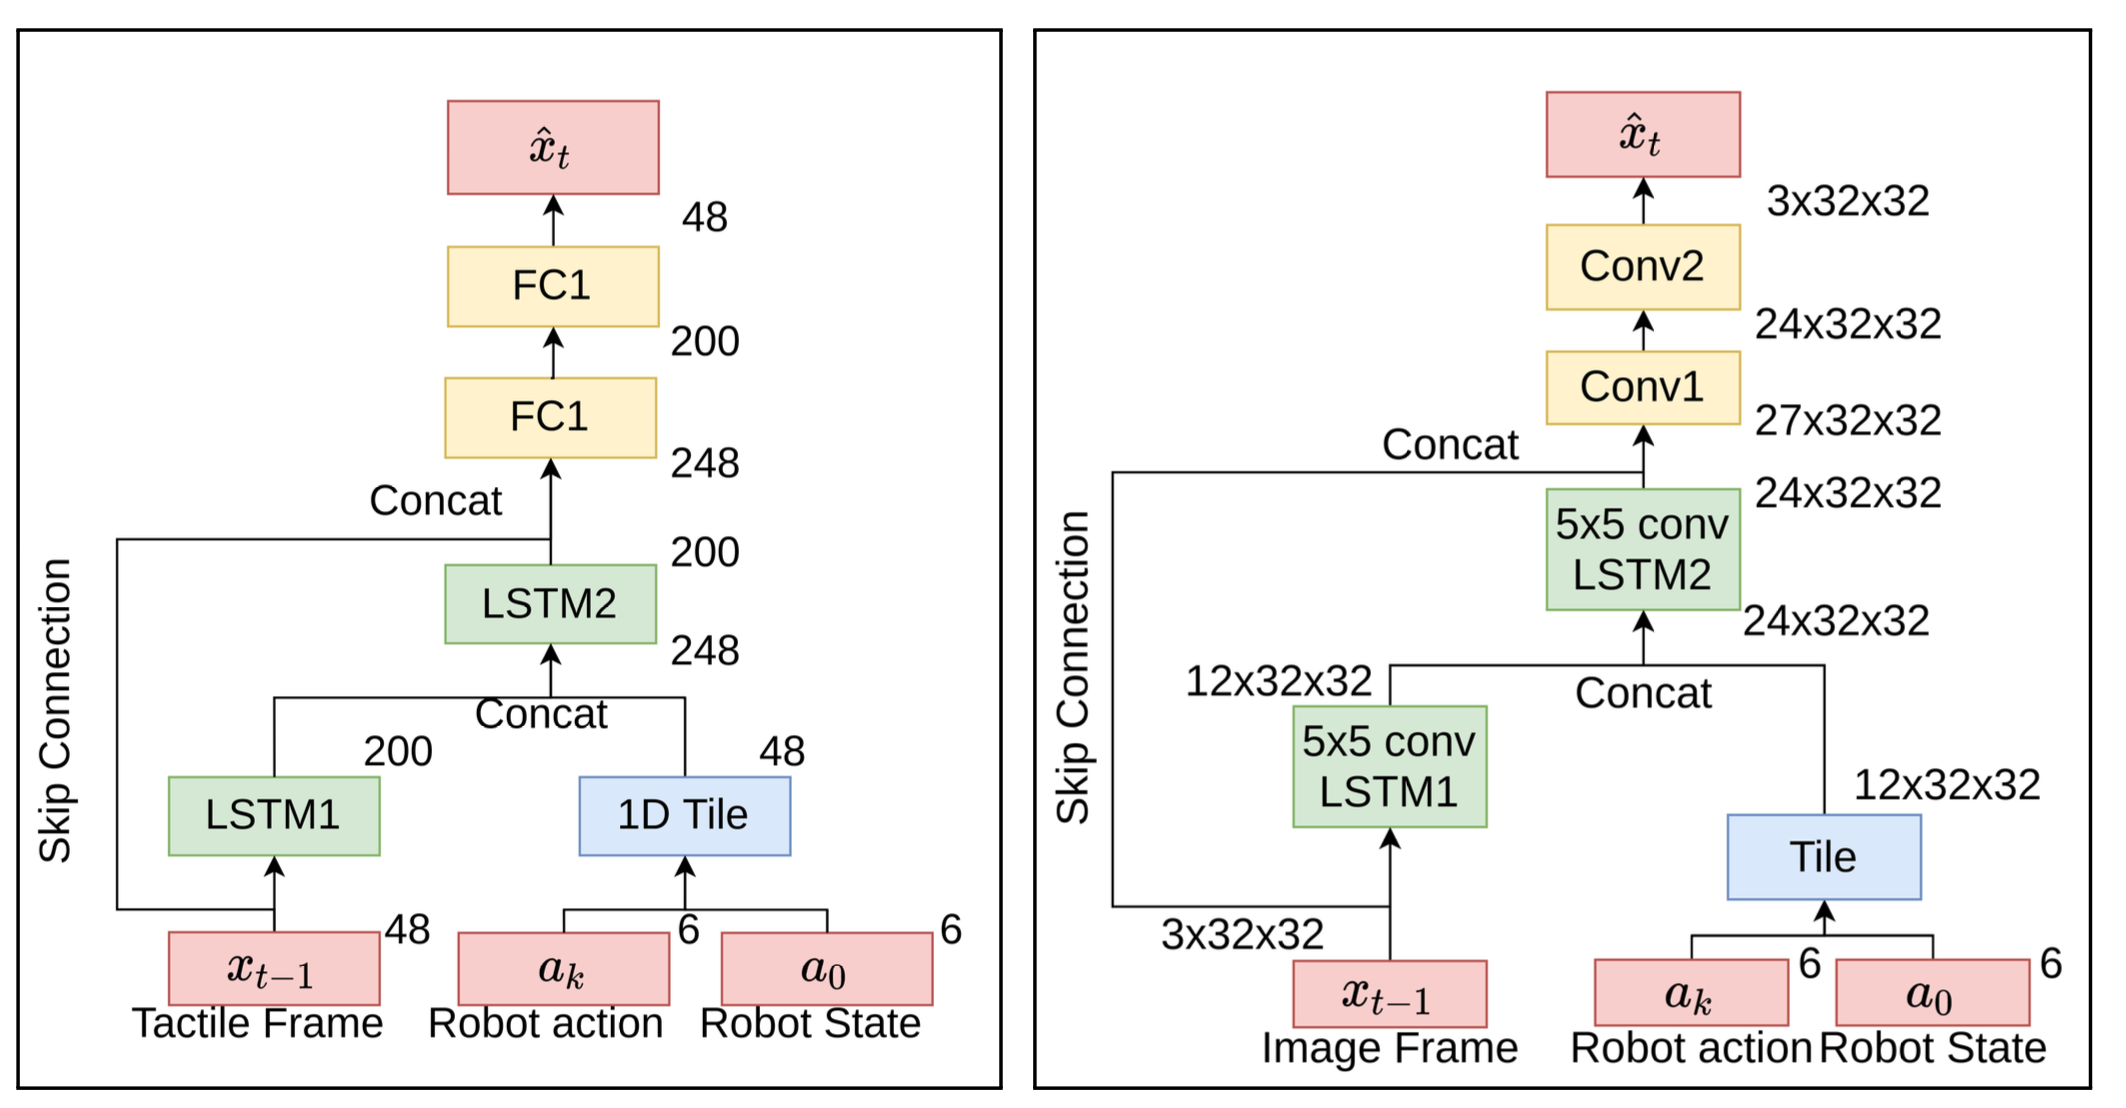
Action Conditioned Tactile Prediction: case study on slip prediction

Paper InfoTitle: Action Conditioned Tactile Prediction: case study on slip predictionVenue: Robotics: Science and Systems (RSS) 2022Keywords: Action-Conditioned Tactile Prediction, Tactile Sensing, Future Tactile Prediction, Slip Prediction, Robot Manipulation, Predictive ControlSummary로봇이 물체를 안정적으로 grasp하고 manipulation하기 위해서는 현재 접촉 상태를 파악하는 것뿐 아니라, 앞으로 수행할 robot action에 의해 tactile response가 어떻게..
Paper 2026.08.17

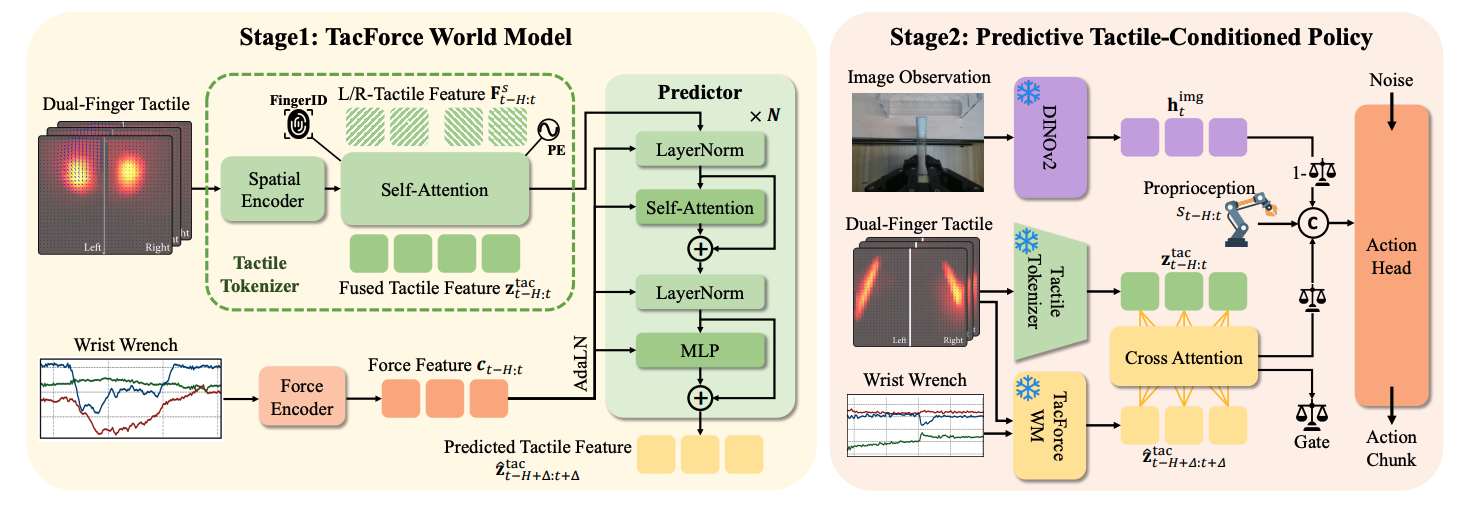
TacForeSight: Force-Guided Tactile World Model for Contact-Rich Manipulation

Paper InfoTitle: TacForeSight: Force-Guided Tactile World Model for Contact-Rich ManipulationVenue: arXiv 2026Keywords: Contact-Rich Manipulation, Tactile World Model, Force-Tactile Prediction, Wrist Force/Torque, Predictive Control, Multimodal ManipulationSummary실제 로봇의 contact-rich manipulation에서는 단순히 물체의 위치를 인식하고 정해진 trajectory를 따라 움직이는 것만으로는 안정적인 작업 수행이 어렵다. 삽입, 밀기, 닦기, 회전과 같이 지속적인 물리적 접촉이 발생..

Paper 2026.08.16

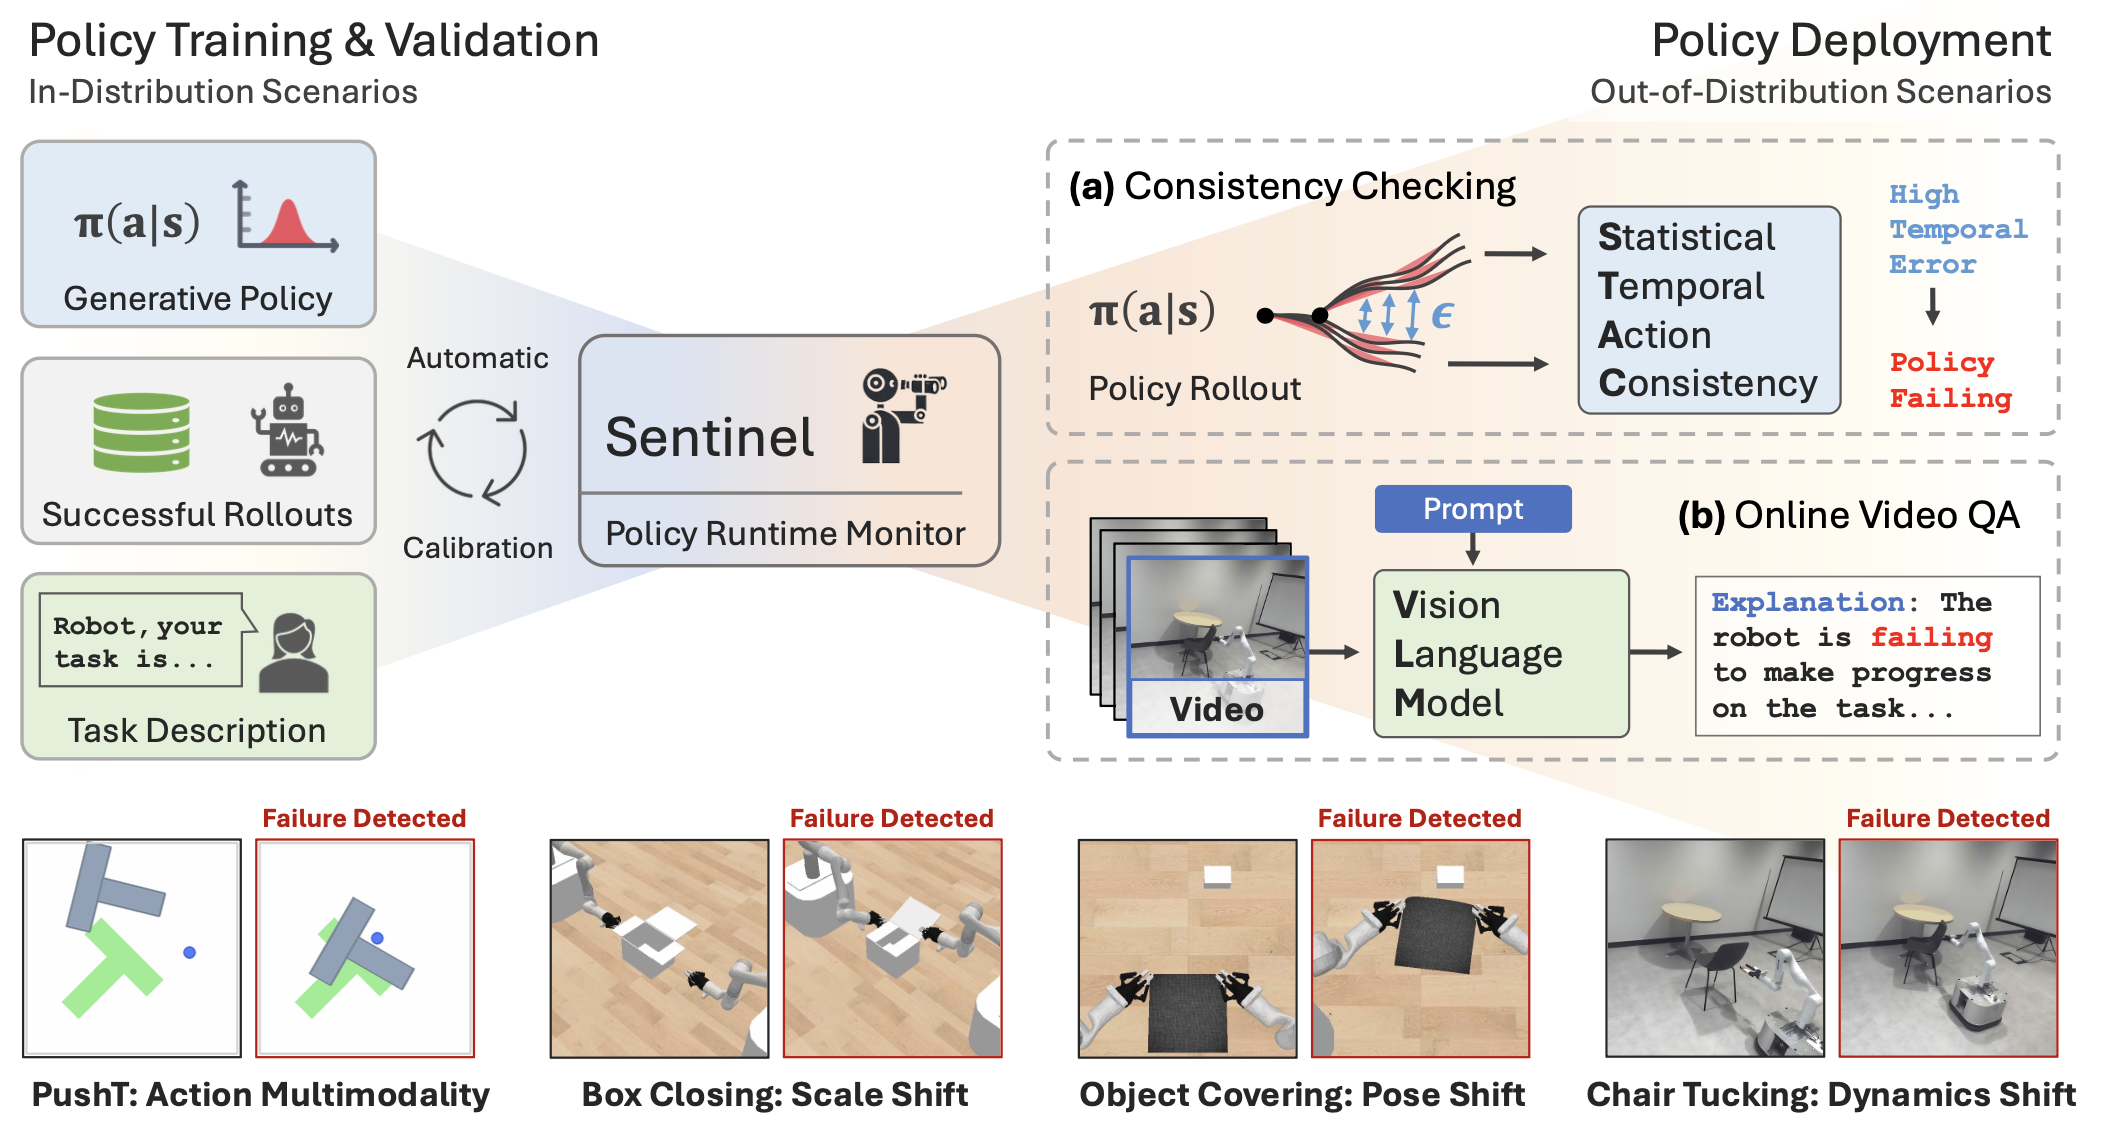
Unpacking Failure Modes of Generative Policies:Runtime Monitoring of Consistency and Progress

Paper InfoTitle: Unpacking Failure Modes of Generative Policies: Runtime Monitoring of Consistency and ProgressVenue: CoRL 2024Keywords: Generative Robot Policy, Failure Detection, Runtime Monitoring, Temporal Action Consistency, Vision Language Model, Out-of-Distribution DetectionSummary최근 Diffusion Policy와 같은 생성형 모방학습(Generative Imitation Learning)은 다양한 human demonstration으로부터 복잡한 로봇 행동을 학습하고,..

Paper 2026.08.14

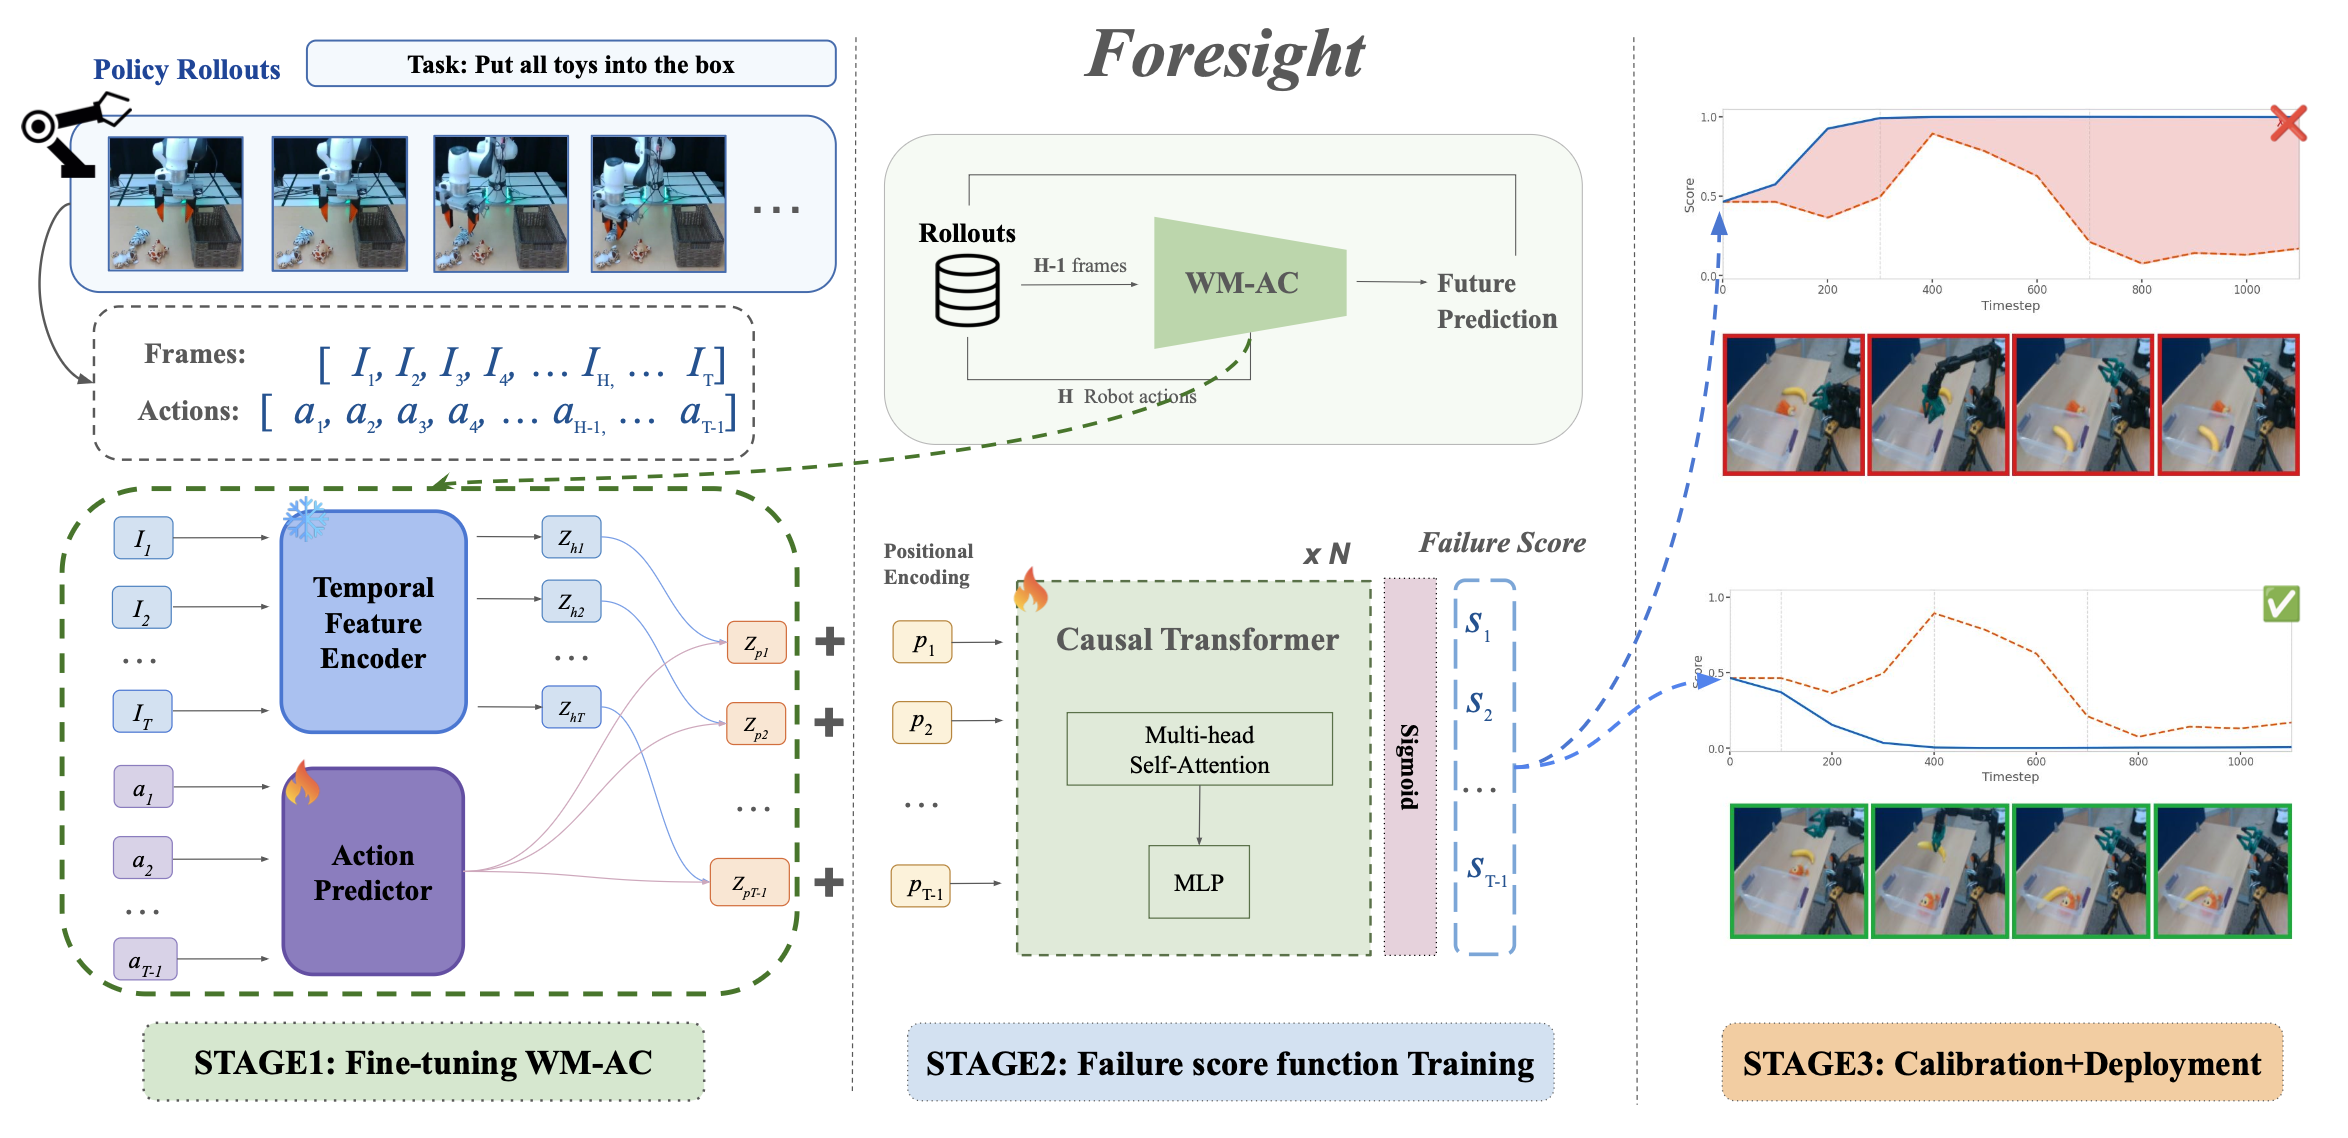
Foresight: Failure Detection for Long-HorizonRobotic Manipulation with Action-ConditionedWorld Model Latents

Paper InfoTitle: Foresight: Failure Detection for Long-Horizon Robotic Manipulation with Action-Conditioned World Model LatentsVenue: arXiv 2026Keywords: Long-Horizon Robotic Manipulation, Failure Detection, Action-Conditioned World Model, World Model Latent, Runtime Monitoring, Conformal PredictionSummary실제 로봇이 수행하는 manipulation task는 하나의 단순한 행동으로 끝나는 경우보다 여러 개의 subgoal이 연속적으로 연결되는 long-horizon..

Paper 2026.08.13

Failure Prediction at Runtime forGenerative Robot Policies

Paper InfoTitle: Failure Prediction at Runtime for Generative Robot PoliciesVenue: NeurIPS 2025Keywords: Generative Robot Policy, Failure Prediction, Runtime Monitoring, Imitation Learning, Out-of-Distribution Detection, Action UncertaintySummary최근 Diffusion Policy와 Flow Matching 기반 정책과 같은 생성형 모방학습(Generative Imitation Learning)은 복잡하고 장기적인 로봇 조작 작업에서 높은 성능을 보이고 있다. 그러나 실제 배포 환경에서는 학습 중 보지 못한 물체나..

Paper 2026.08.13

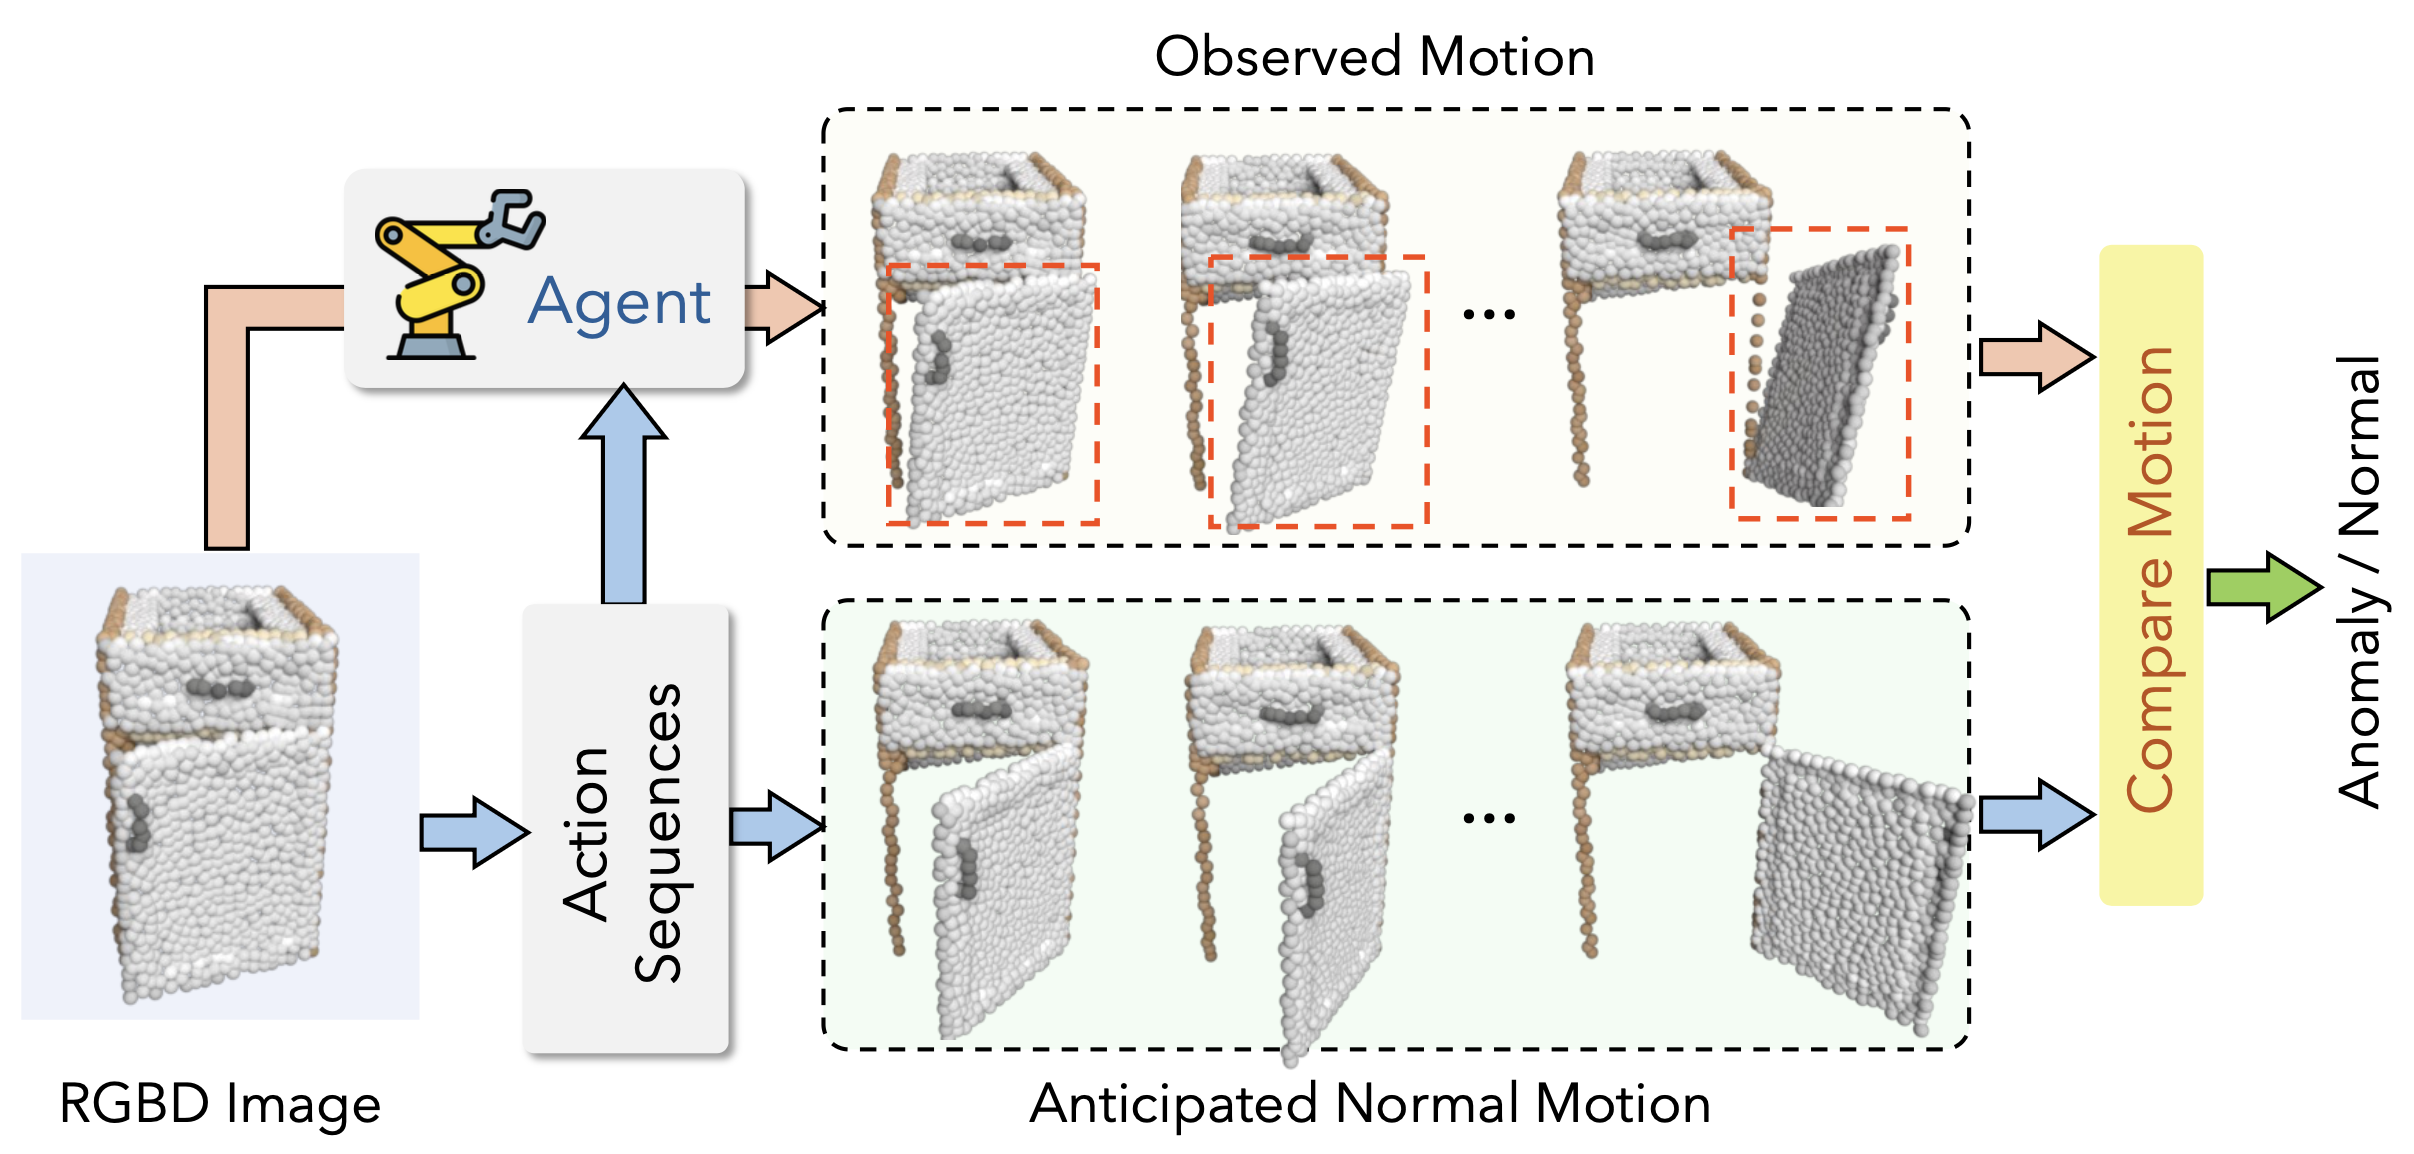
Interactive Anomaly Detection for Articulated Objectsvia Motion Anticipation

Summary기존 이상 탐지(Anomaly Detection, AD)는 주로 이미지, 비디오, 포인트 클라우드와 같은 정적 관찰을 기반으로 정상과 비정상을 구분한다. 그러나 서랍, 문, 노트북과 같은 관절형 물체(articulated object)는 외관상 정상으로 보여도 실제 조작 과정에서 끝까지 열리지 않거나, 예상과 다른 방향으로 움직이거나, 정상적인 운동 범위를 벗어나는 기능 이상(functional anomaly)이 존재할 수 있다. 이러한 이상은 물체를 실제로 움직여 보기 전에는 확인하기 어렵다.이는 기존 이상 탐지와 다른 문제를 만든다. 기능 이상을 발견하려면 단순히 물체를 관찰하는 것뿐 아니라, 어떤 행동을 수행해야 이상이 드러나는지 결정하고, 그 행동에 대해 정상 물체가 어떻게 움직여야 ..

Paper 2026.08.09

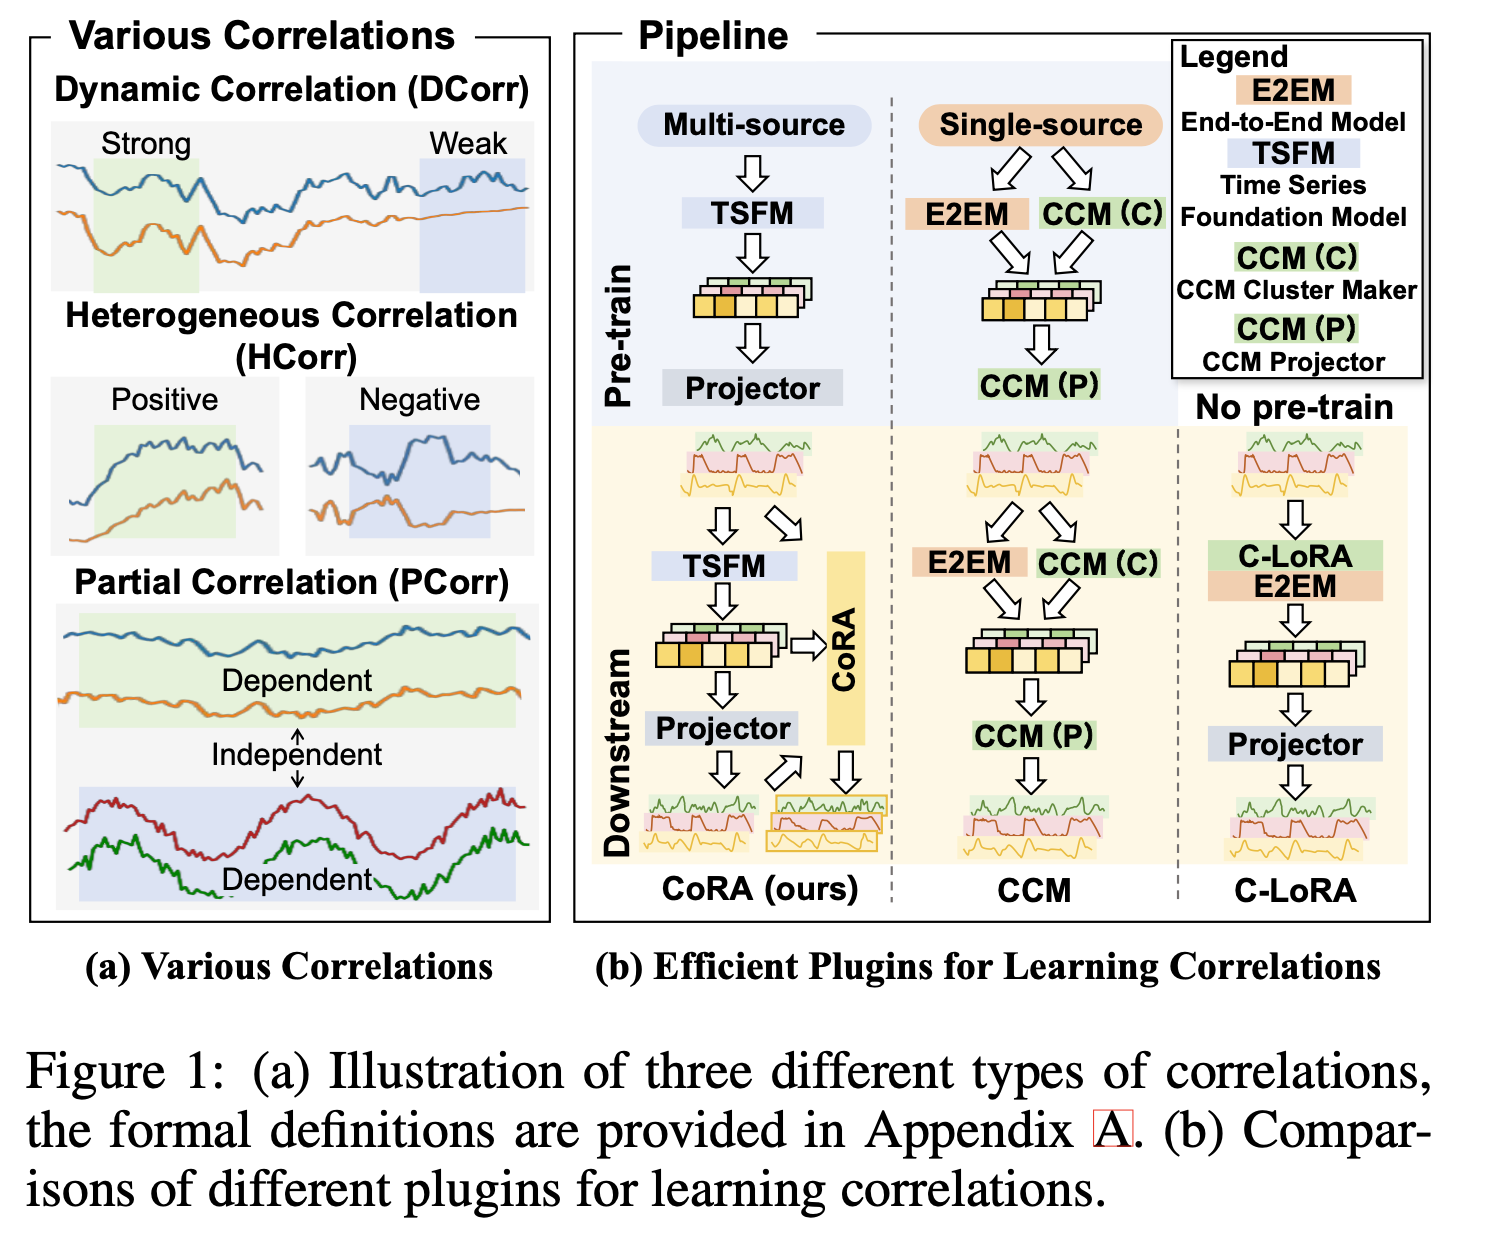
CORA: BOOSTING TIME SERIES FOUNDATION MODELS FOR MULTIVARIATE FORECASTING

Summary최근 시계열 파운데이션 모델(Time Series Foundation Model, TSFM)은 대규모 시계열 데이터를 사전학습하거나 대규모 언어모델의 표현 능력을 활용하면서, 새로운 데이터에서도 높은 일반화 성능을 보이고 있다. 그러나 대부분의 TSFM은 각 채널의 시간적 패턴을 학습하는 데 집중하며, 채널 간 관계는 충분히 고려하지 않는 구조를 사용한다.이는 다변량 시계열 예측에서 중요한 한계이다. 다변량 데이터의 예측 성능은 개별 채널의 과거 변화뿐 아니라 여러 채널이 서로 어떻게 연결되는지를 얼마나 적절하게 모델링하는지에 따라 달라지기 때문이다.논문은 이러한 채널 관계를 세 가지로 구분한다. 첫째, 동적 상관관계(Dynamic Correlation, DCorr)는 채널 간 관계가 시간에..

Paper 2026.08.02